ANTRAC UGV
An anthracnose detection field robot: the vehicle, its drive, and its perception. Built and launched by IPB University in May 2025 as one of three national agricultural technology innovations, and presented to the Deputy Minister of Agriculture.
Chilli anthracnose spreads faster than a person can walk it. Scouting is done by eye, row by row, and conventional treatment is a blanket spray over healthy plants as well as infected ones. In a crop where the fruit is the product, both the scouting delay and the wasted chemical cost money.
The machine has to do three physical things at once. It has to cross uneven, loose soil without losing the sensor head's line of sight to the canopy. It has to carry motors, pumps, and a compute board on one battery budget without browning out the controller. And it has to hold a stable view of the canopy while moving, because every later decision depends on that detection. The field is also a workshop problem: anything that breaks has to be repairable with hand tools, because there is no clean room at the edge of a field.
Dosing sits outside this project. It came later, as the final project, which forks this platform and replaces the sprayer with a controlled station.
Chassis and drivetrain design in Fusion 360, workshop fabrication (machining, welding, 3D printing), electrical layout and wiring, and radio control of the drive.
Training and evaluation of the vision model, operator web dashboard, and agronomy parameters on where and how much to spray.
Jetson Nano, ESP32 modules, 240 W DC drive motor and controller, relays, DC-DC converters, and pump set. Off-the-shelf components.
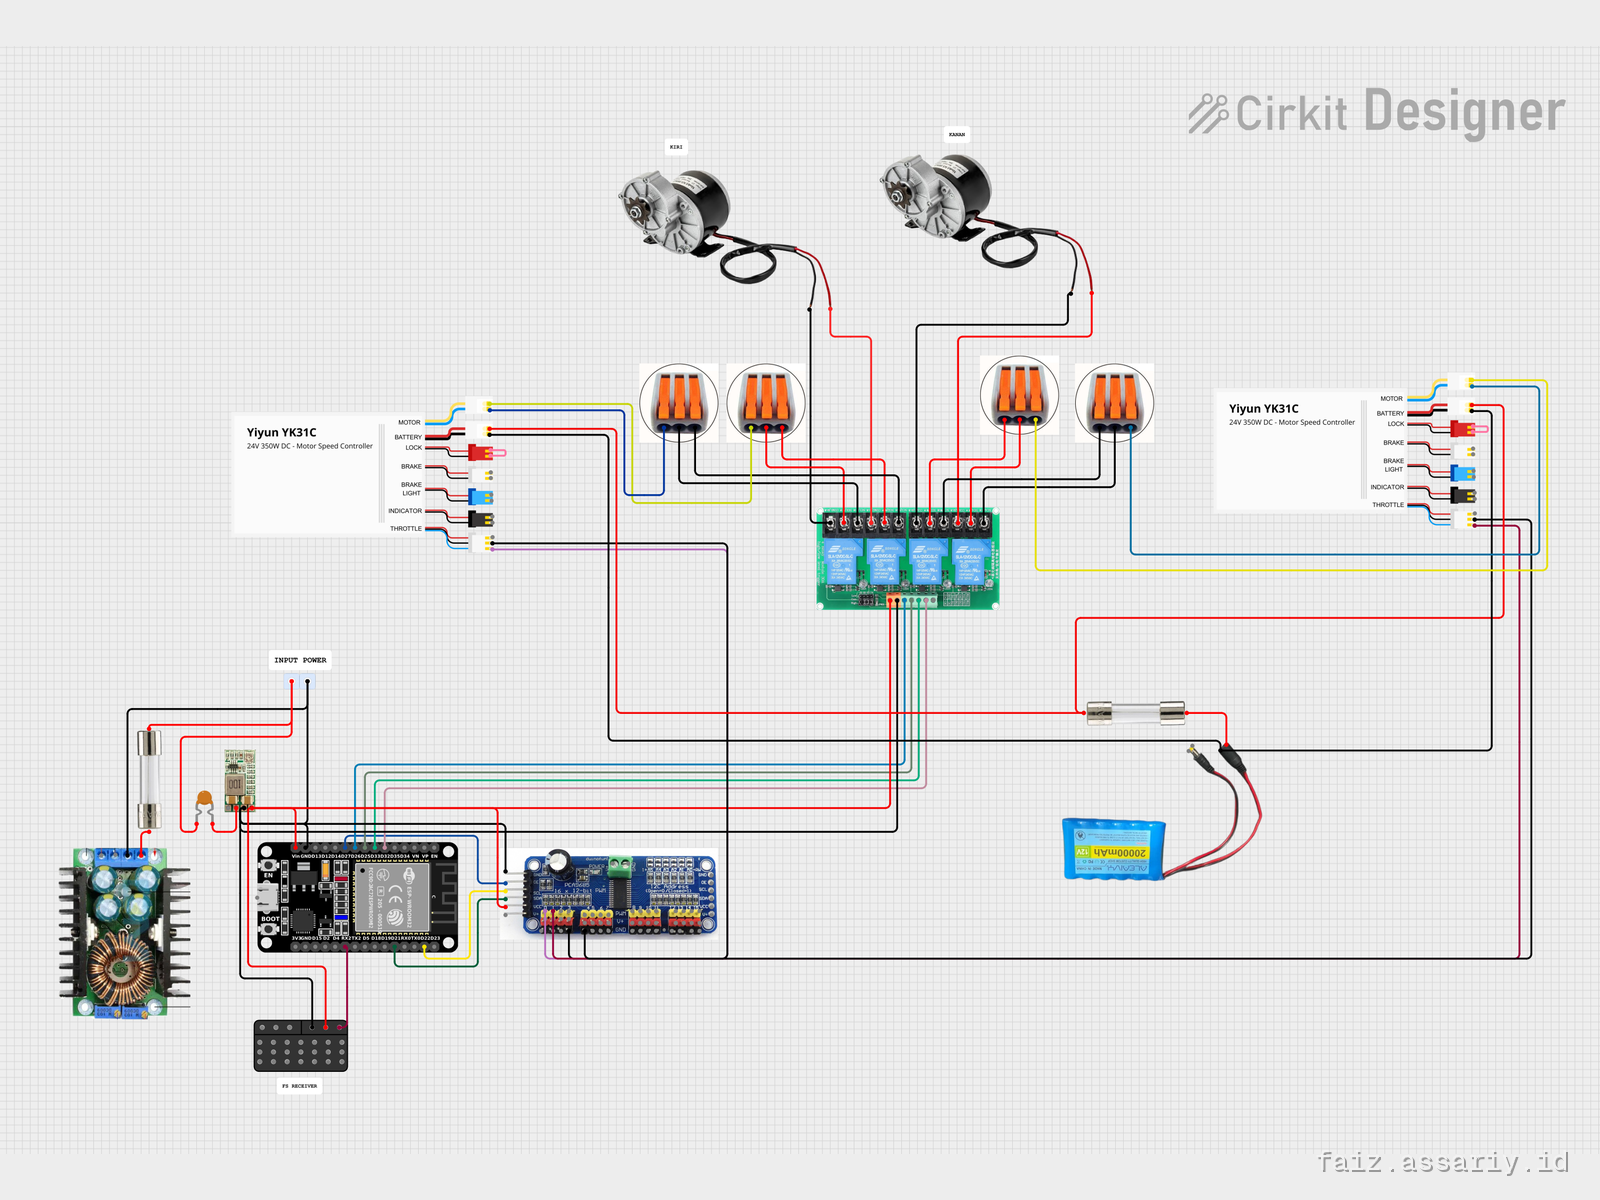
One battery feeds two stages: a motor bus through the drive controllers and a relay bank, and an isolated logic rail through the DC-DC converter for the ESP32 and sensor head. The drawing is the version that was built, not an idealised schematic.
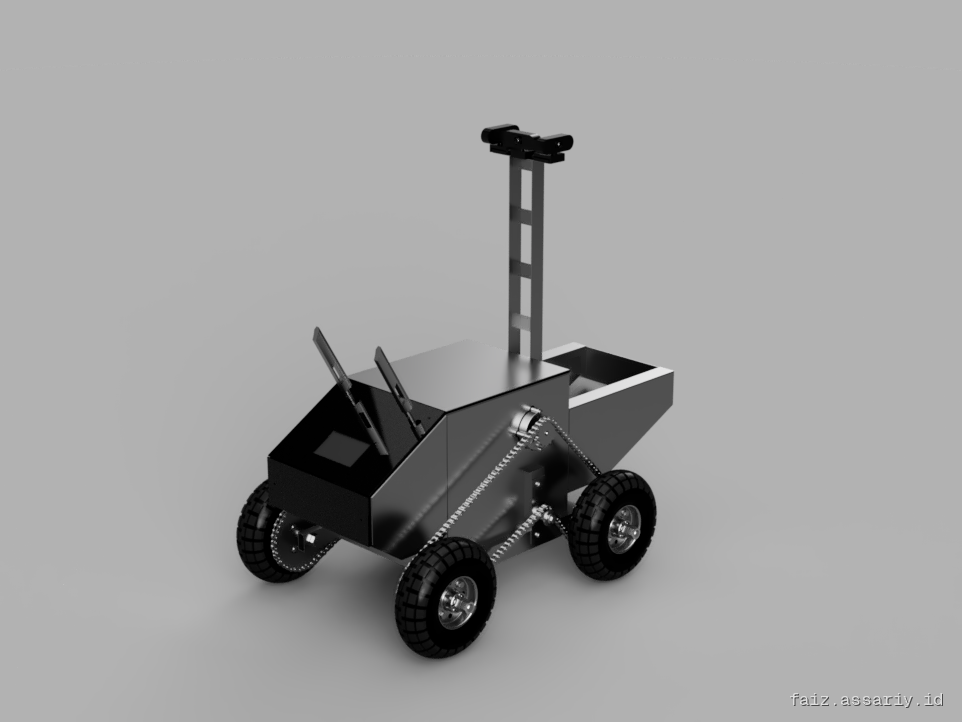
Chassis, suspension and payload mounts modelled around stock profiles and plate that the workshop could actually cut and weld.
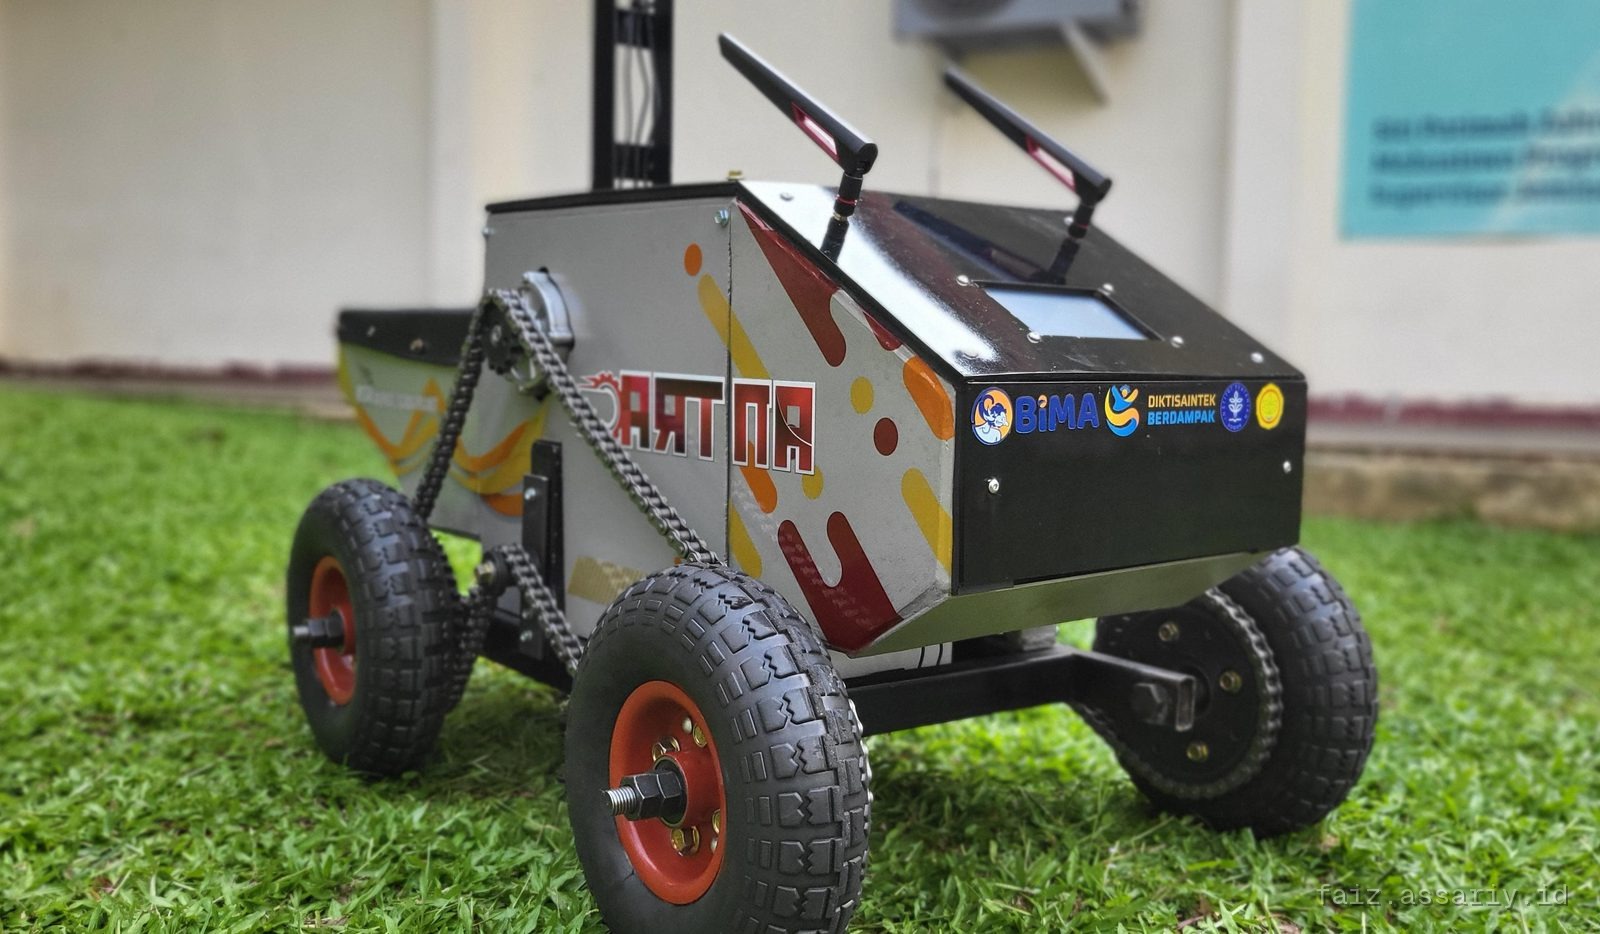
Cut, weld, machine and print the structure, then fit the drive, the mast head and the payload until the assembly matched the model closely enough to wire.
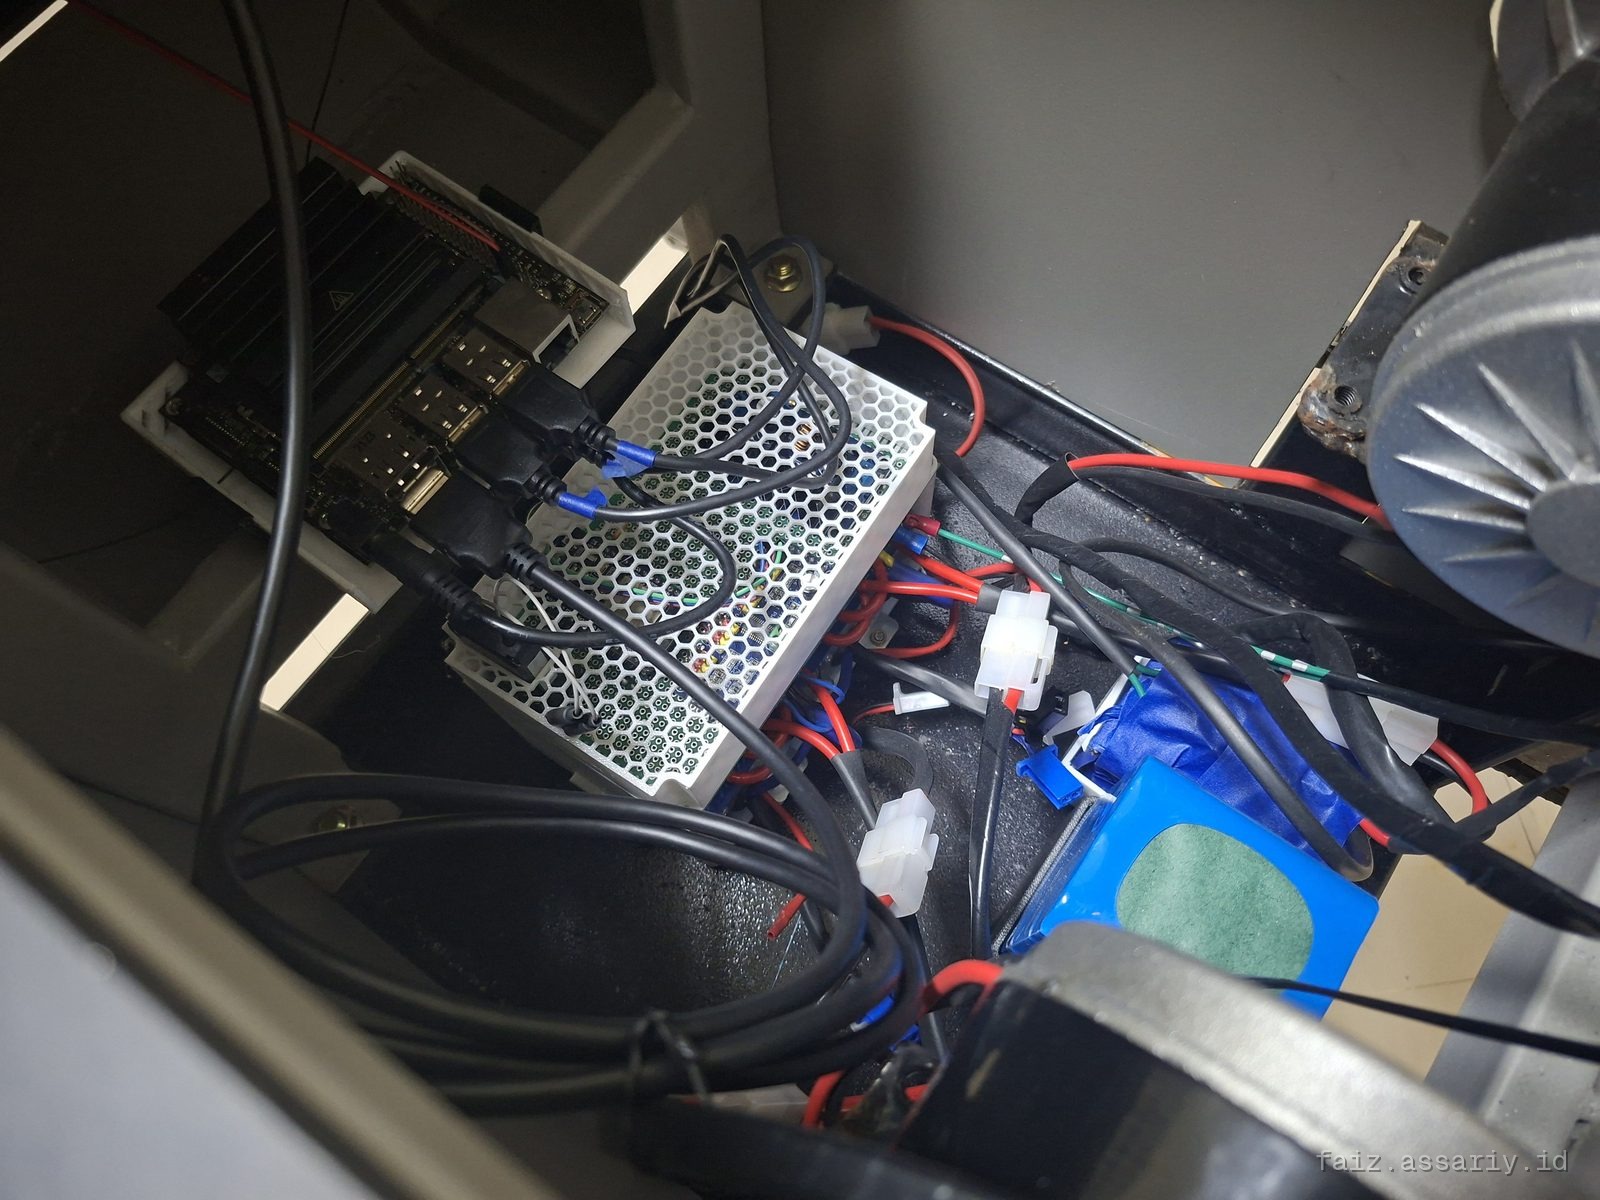
Power distribution and grounding laid out by hand. Motor inrush pulled the logic rail down until the grounds and the DC-DC input were separated.
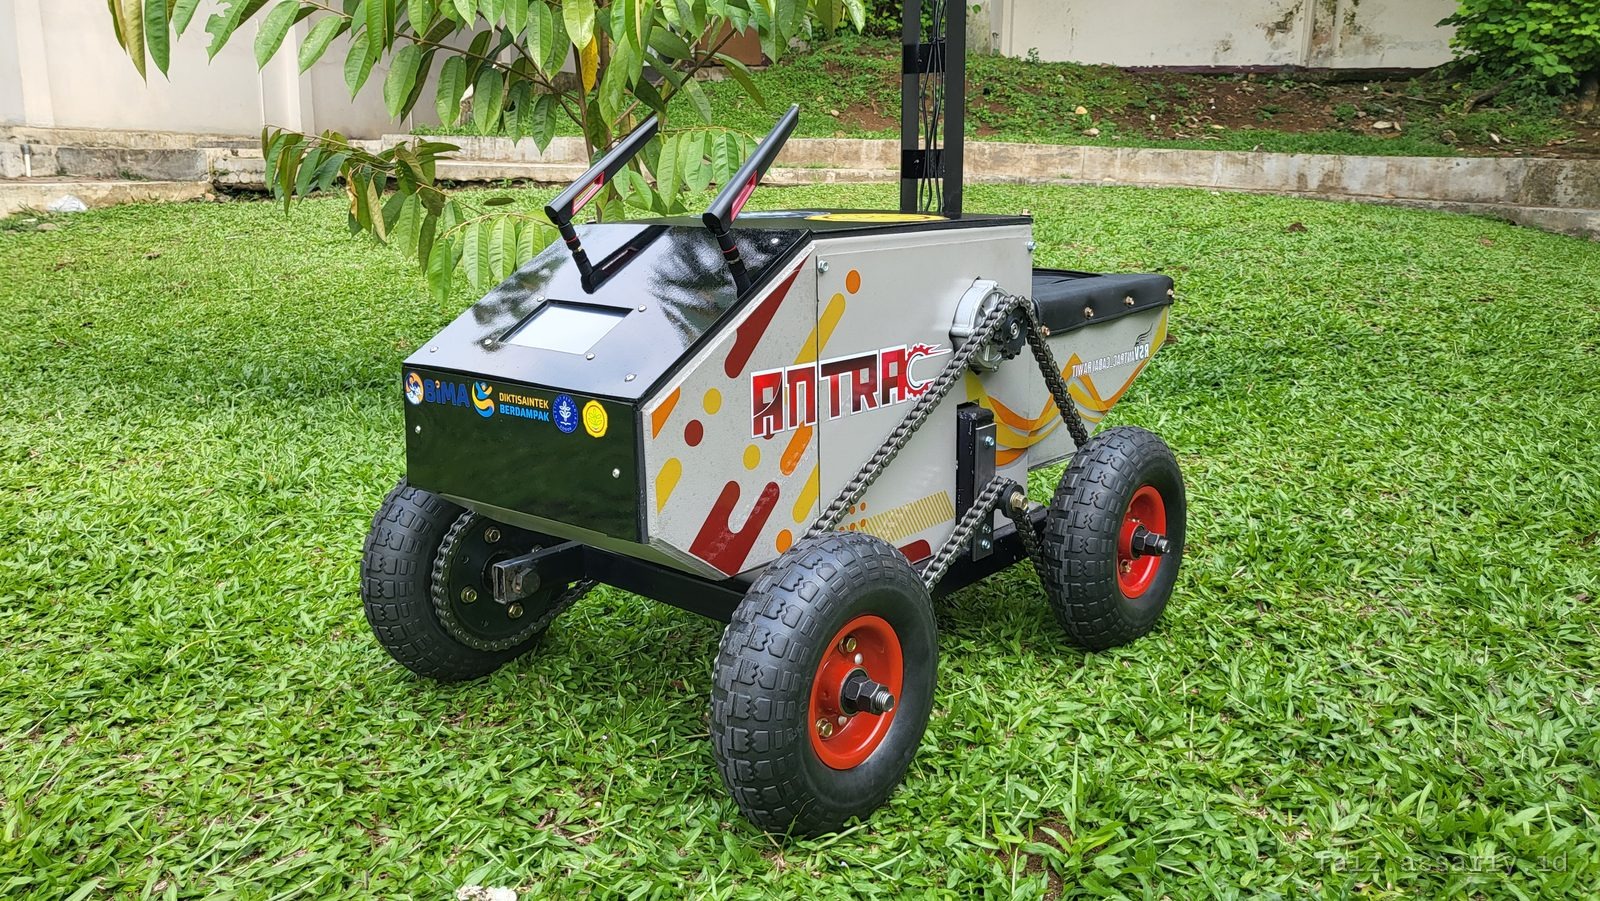
Drive and steering exercised on grass before the launch. The recovery of the drive controller's protocol happened here, by measurement.
| Claim | Method and conditions | Result | Known shortfall and next fix |
|---|---|---|---|
| Radio control of the 240 W drive | The supplied controller had no protocol documentation. The control path was recovered by measurement, then exercised on the bench and on grass. | Works | No frame format is written down. Rev 2 documents the recovered protocol so the next build does not repeat the work. |
| Anthracnose detection (perception half, team model) | YOLOv8 trained on field images from three sites in Bogor Regency, dataset prepared in Roboflow. Figures read from the normalised confusion matrix. | 0.45 recall | Anthracnose recall 0.45 against 0.73 for non-anthracnose, and the background class was never predicted (0.00): 91% of true background frames came back as non-anthracnose. Not reliable enough to gate a spray command alone; more anthracnose samples and a real background class are the next step. |
| Field endurance | Repeated runs on grass with the drivetrain and compute bay loaded. | Not instrumented | Battery runtime per hectare was never logged with a meter, so no number is claimed here. |
Perception figures come from the training and validation logs. The dose result belongs to the fork, not to this platform: see the spraying station case.
What broke twice. The logic rail browned out under motor inrush, first on the bench and again on the first grass run, because the initial fix addressed the DC-DC input but missed the shared ground return. The second failure is the useful one: it proved that grounding loops, not supply headroom, were the real constraint.
What changes in Rev 2. A documented protocol table for the 240 W drive controller and a dedicated logic ground bus with a single star point. The dose fixes belong to the fork, not here.
What to test on day one. A loaded drive command with the compute bay drawing at full load, logged at the logic rail, before any field time is booked. That single measurement would have caught both brownouts in an afternoon.